User Guide
Overview
RoboKit is a high-performance, general-purpose toolkit for versatile robotic tasks. It scales from one problem to thousands in parallel. It provides a library of cost terms and optimizers that compose freely. Built-in tasks such as IK, motion planning, and retargeting are validated on real robots.
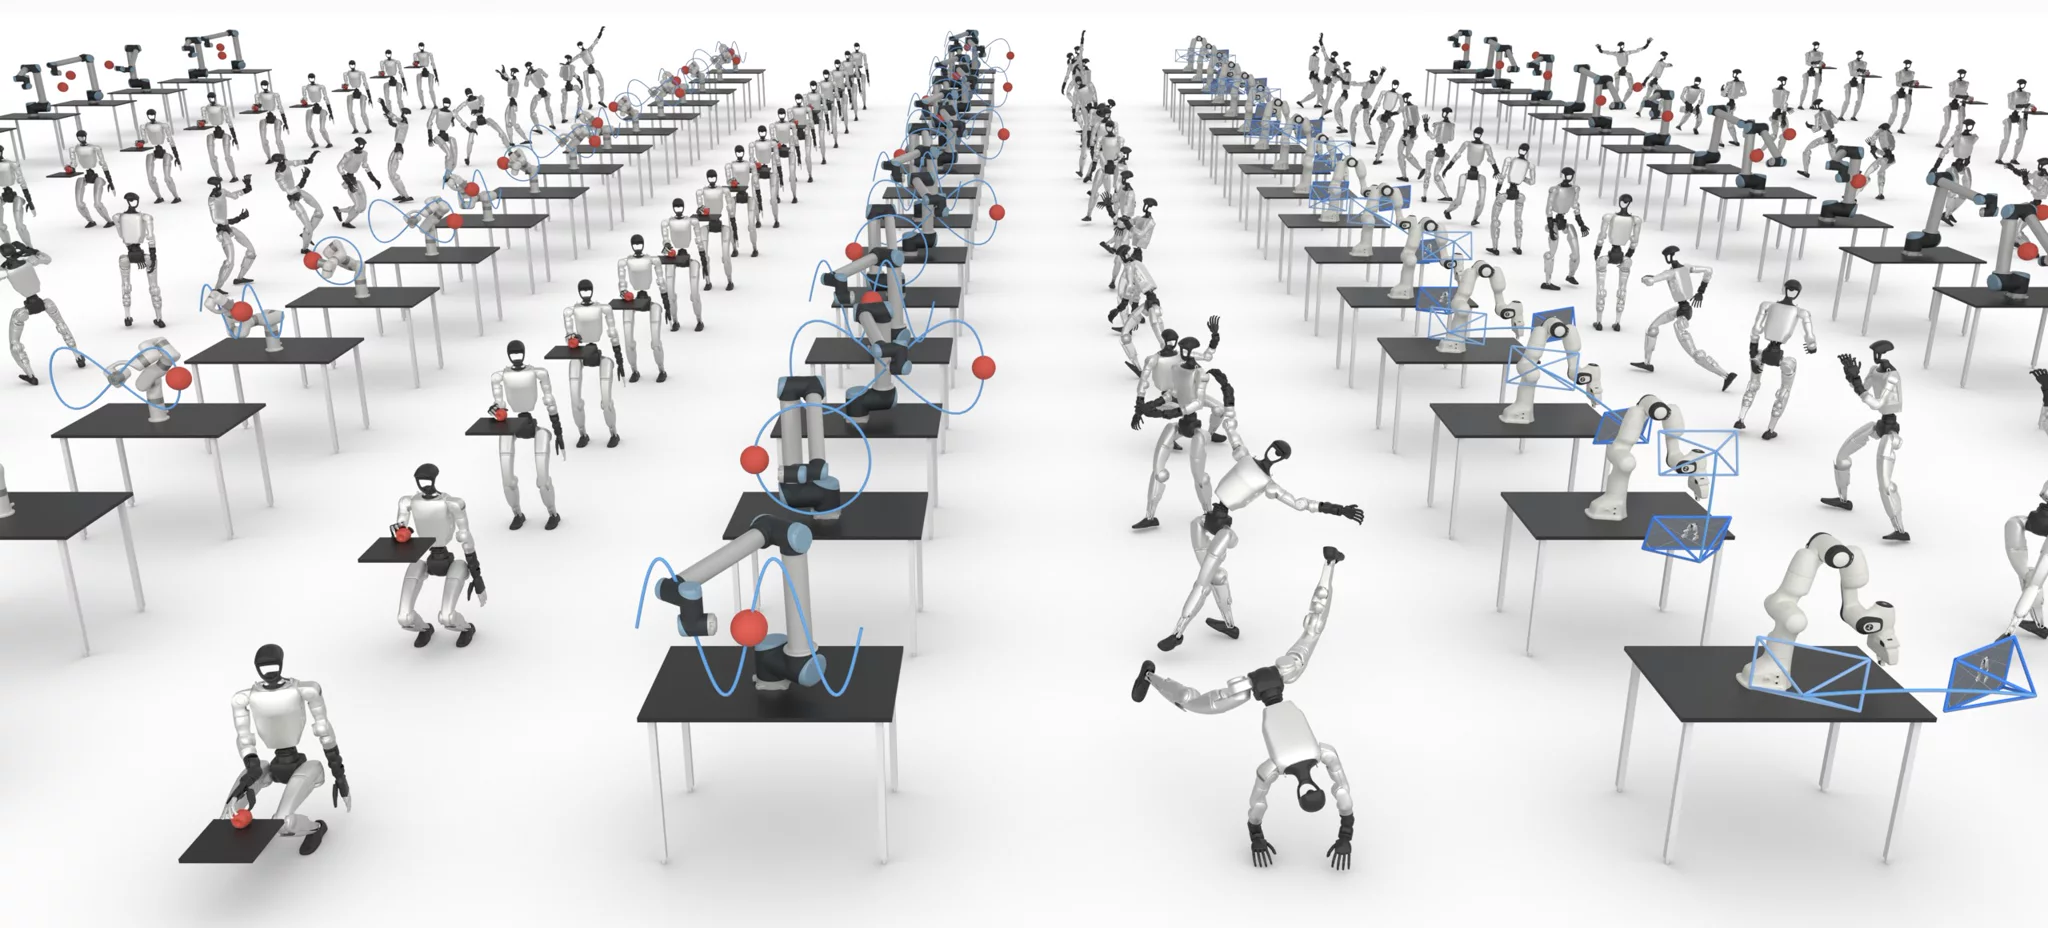
Thousands of robots solving in parallel.
Benchmarks
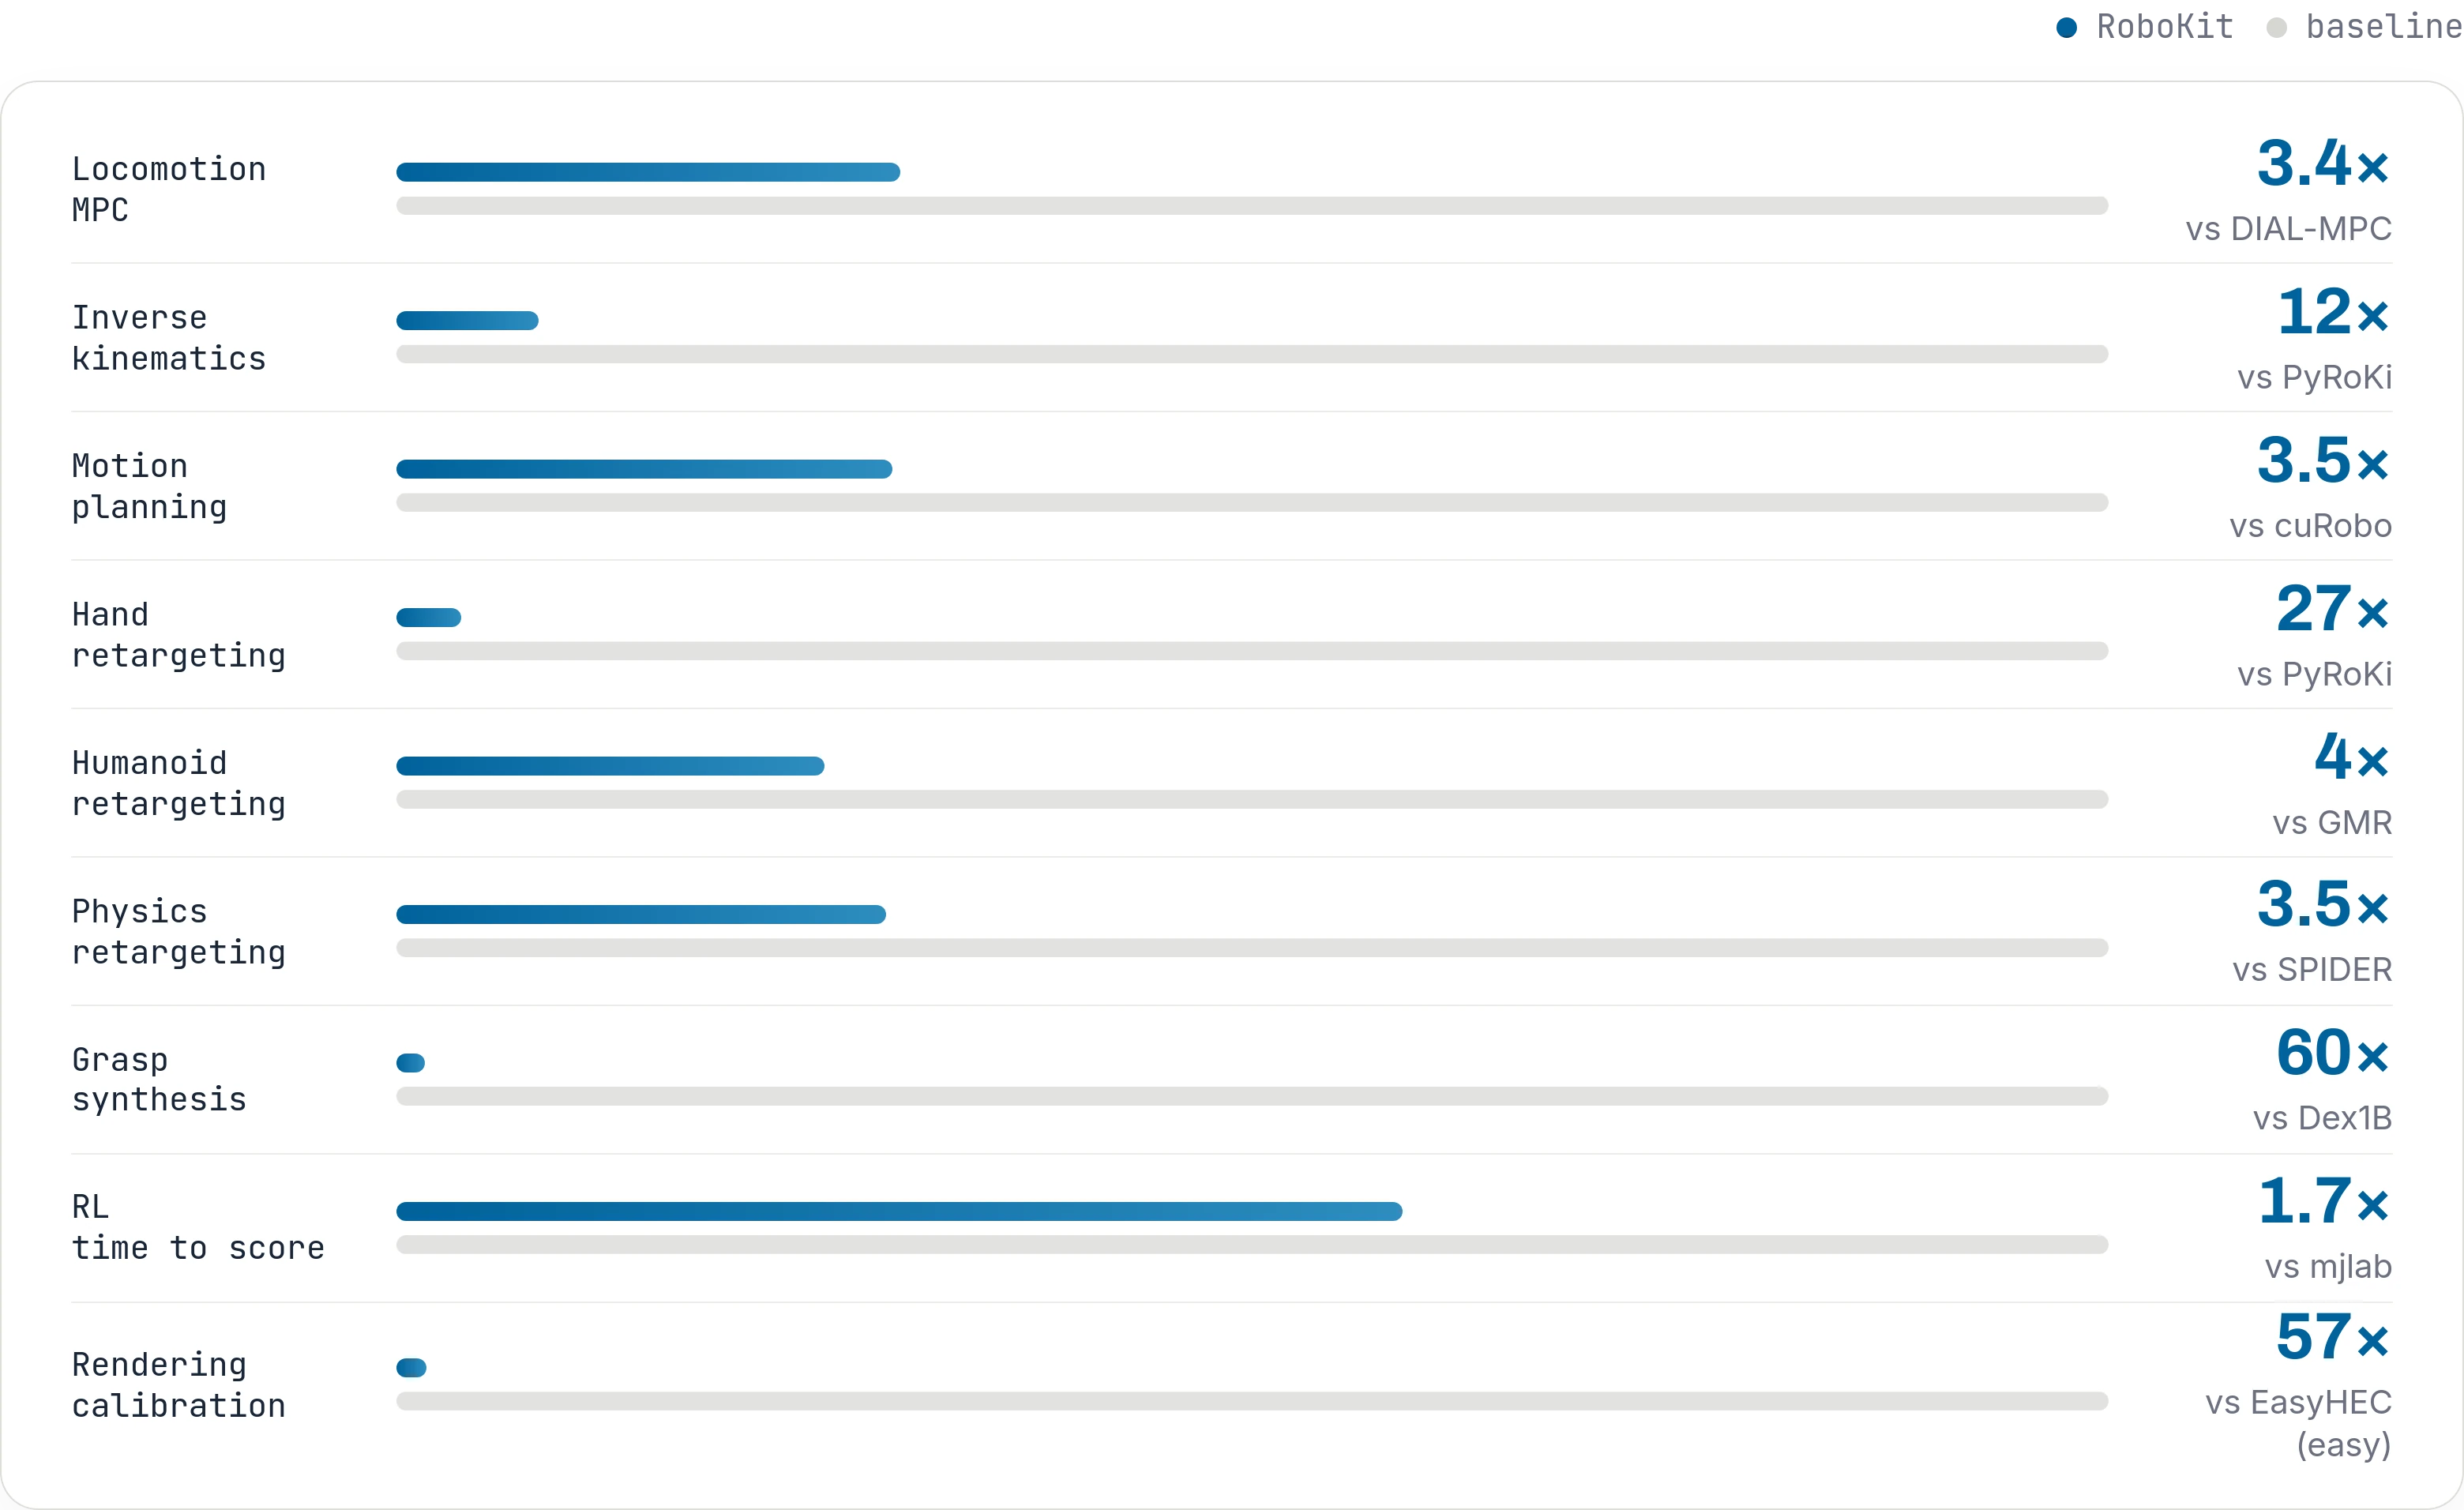
Bars are wall-clock time on the same task, baseline normalized to full width. Check the paper for benchmark details.
Optimization/Learning with Simulation
 |  |  |
|---|---|---|
NIST Assembly RL A Franka puts six NIST board parts in place, one after another (3× speed). | Rough Terrain RL A Go1 walks up and down stairs, following the green velocity command. | Pen Spinning MPC A Sharpa hand spins a pen in its fingers. |
 |  |  |
Notebook Opening MPC Two XHands open a hinged ARCTIC notebook. | Box Carrying MPC A G1 lifts and carries a box. | Climbing MPC A G1 climbs a box on hands and knees. |
Optimization with Analytic Objectives
| IK Multi-link targets, fixed or floating base. | Motion Planning Collision-free trajectories, offline or online. | Hand-Eye Calibration Camera pose from rendered robot masks. |
| Humanoid Retargeting Human motion capture to a humanoid. | Hand Retargeting Human hand motion to a robot hand. | Grasp Optimization Force-closure grasps for any hand or body. |
How it works
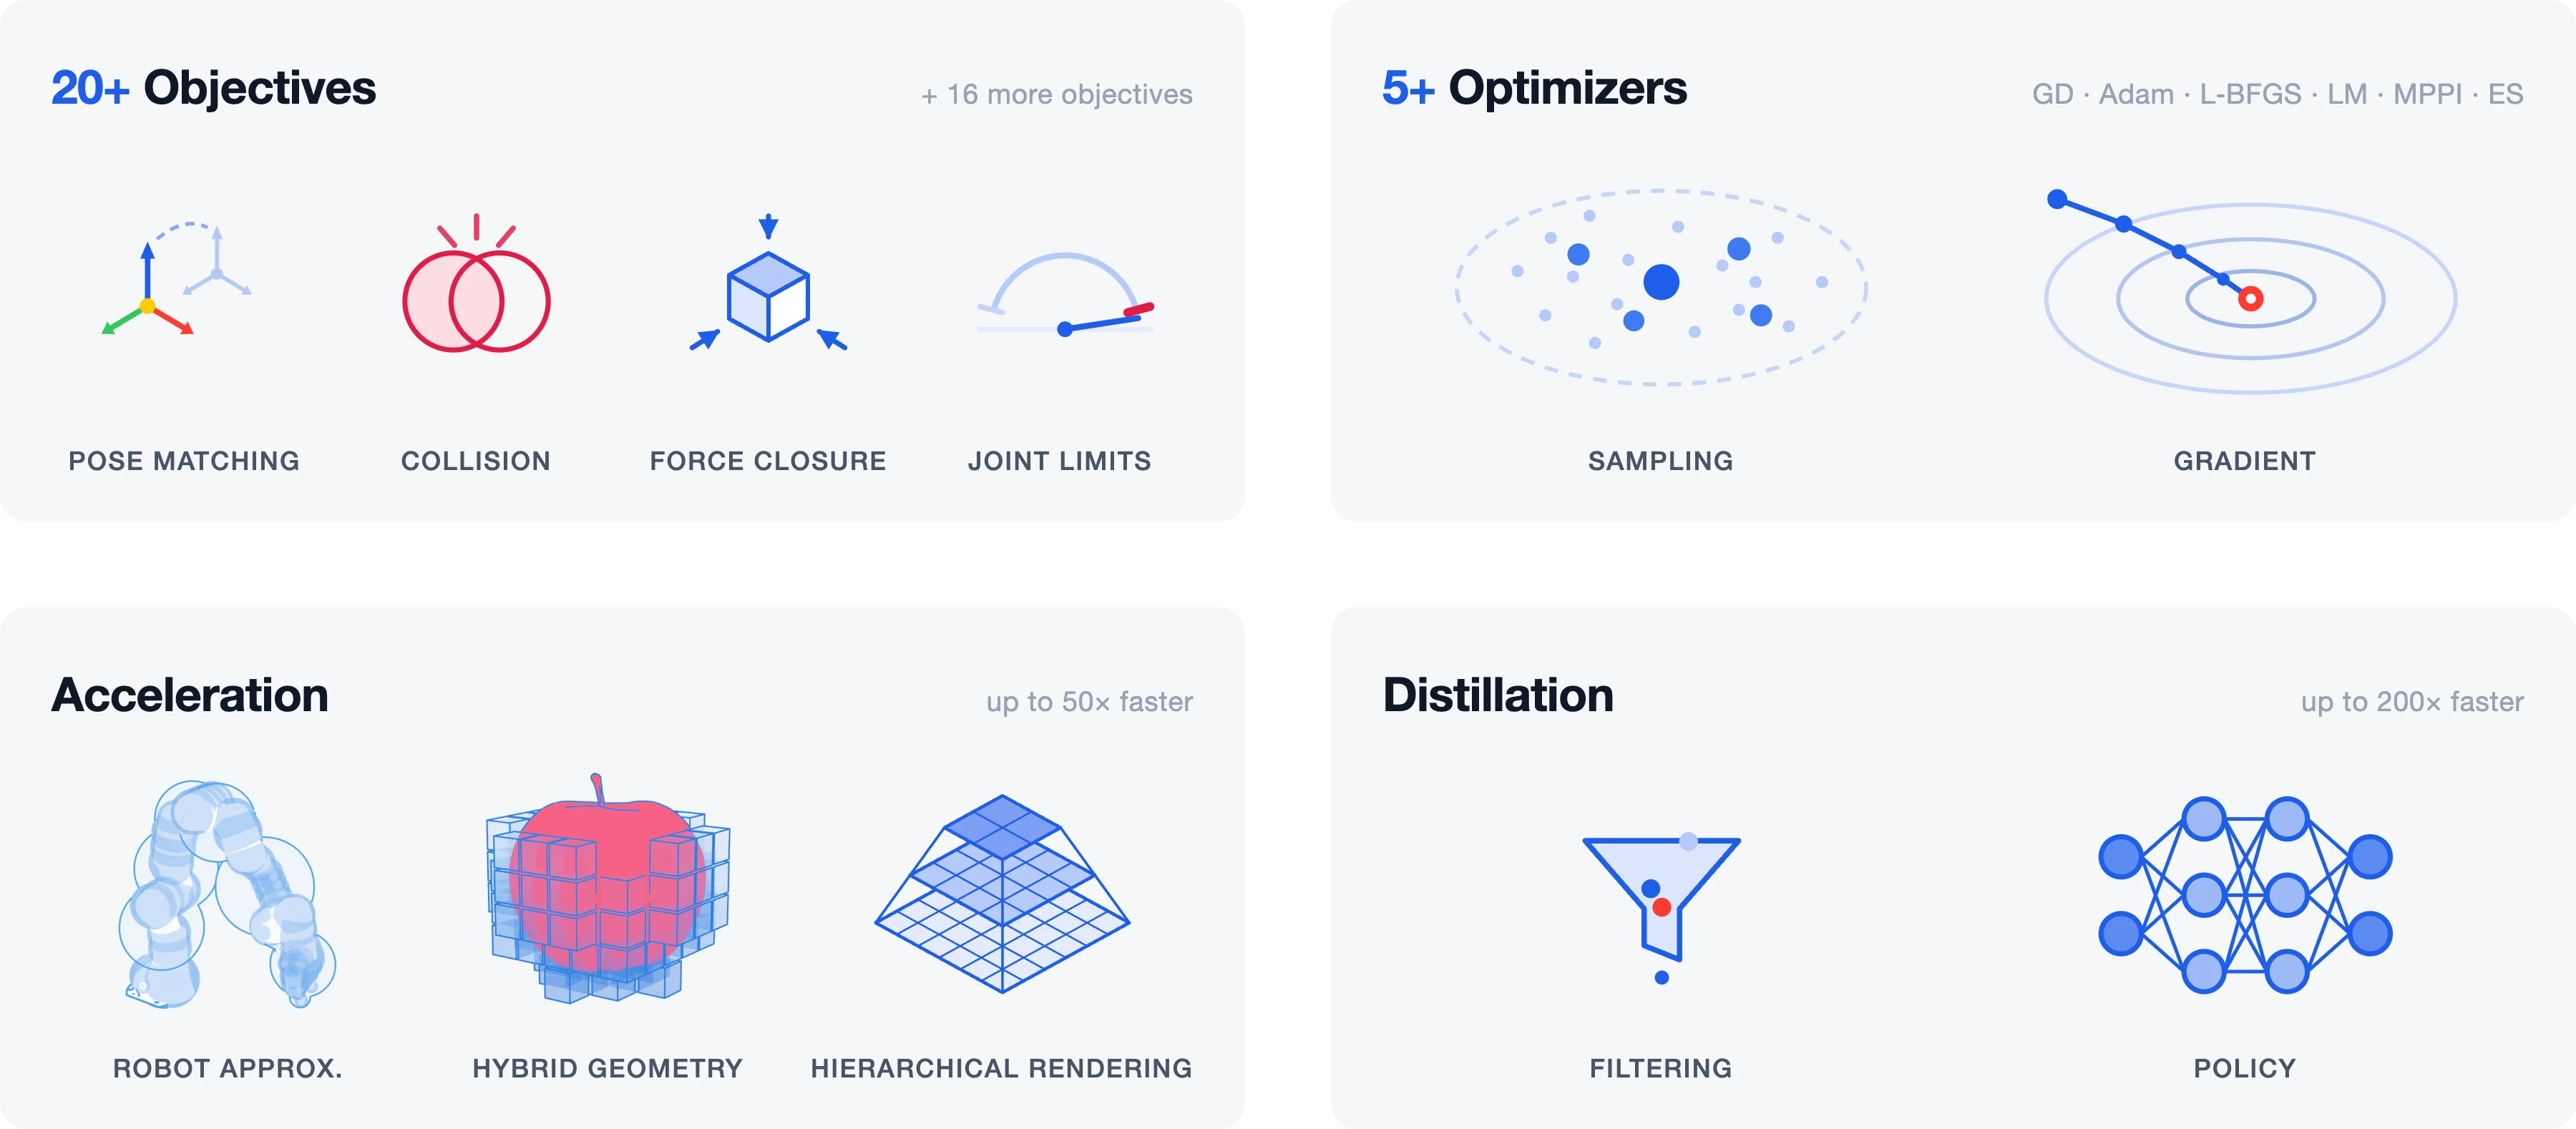
| Component | Role | Read more |
|---|---|---|
| Robot | Load URDF or MJCF models and compute batched, differentiable kinematics. | Robot |
| Objectives | Cost terms that define a task: pose matching, collision, limits, contacts. | Terms |
| Optimizers | Sampling and gradient methods that minimize the objectives in parallel. | Optimization |
| Acceleration | Fast geometry and rendering for contact-rich and calibration tasks. | Geometry |
| Distillation | Train policies on solver outputs for even faster inference. |
Installation
Requires Python 3.8 or newer:
uv add robokit # or: pip install robokit
PyTorch is optional. See Installation for source installs and extras.
Quick links
Citation
@inproceedings{ye2026robokit,
  title     = {RoboKit: Accelerating Parallel Differentiable Optimization for Robot Learning},
  author    = {Ye, Jianglong and Peng, Xuanbin and Mc Gartoll, Conor and Jing, Changwei and Wei, Lai and Chen, Jiali and Zou, Xueyan and Wang, Xiaolong},
  booktitle = {Conference on Robot Learning (CoRL)},
  year      = {2026}
}